Welcome!
The Autonomous Navigation and Perception Lab performs research related to single and multi-robot autonomous perception, navigation and planning under uncertainty in the context of mobile robotics. Research in the lab is highly multidisciplinary, involving both fundamental theoretical studies and experimental verification. Please visit Research and Publications pages to see ongoing research activities. The lab was founded by Assoc. Prof. Vadim Indelman in 2014.
We are always looking for highly-motivated individuals to join our group, see details here.
Recent News & Updates
@ANPL_Technion
Nov 13
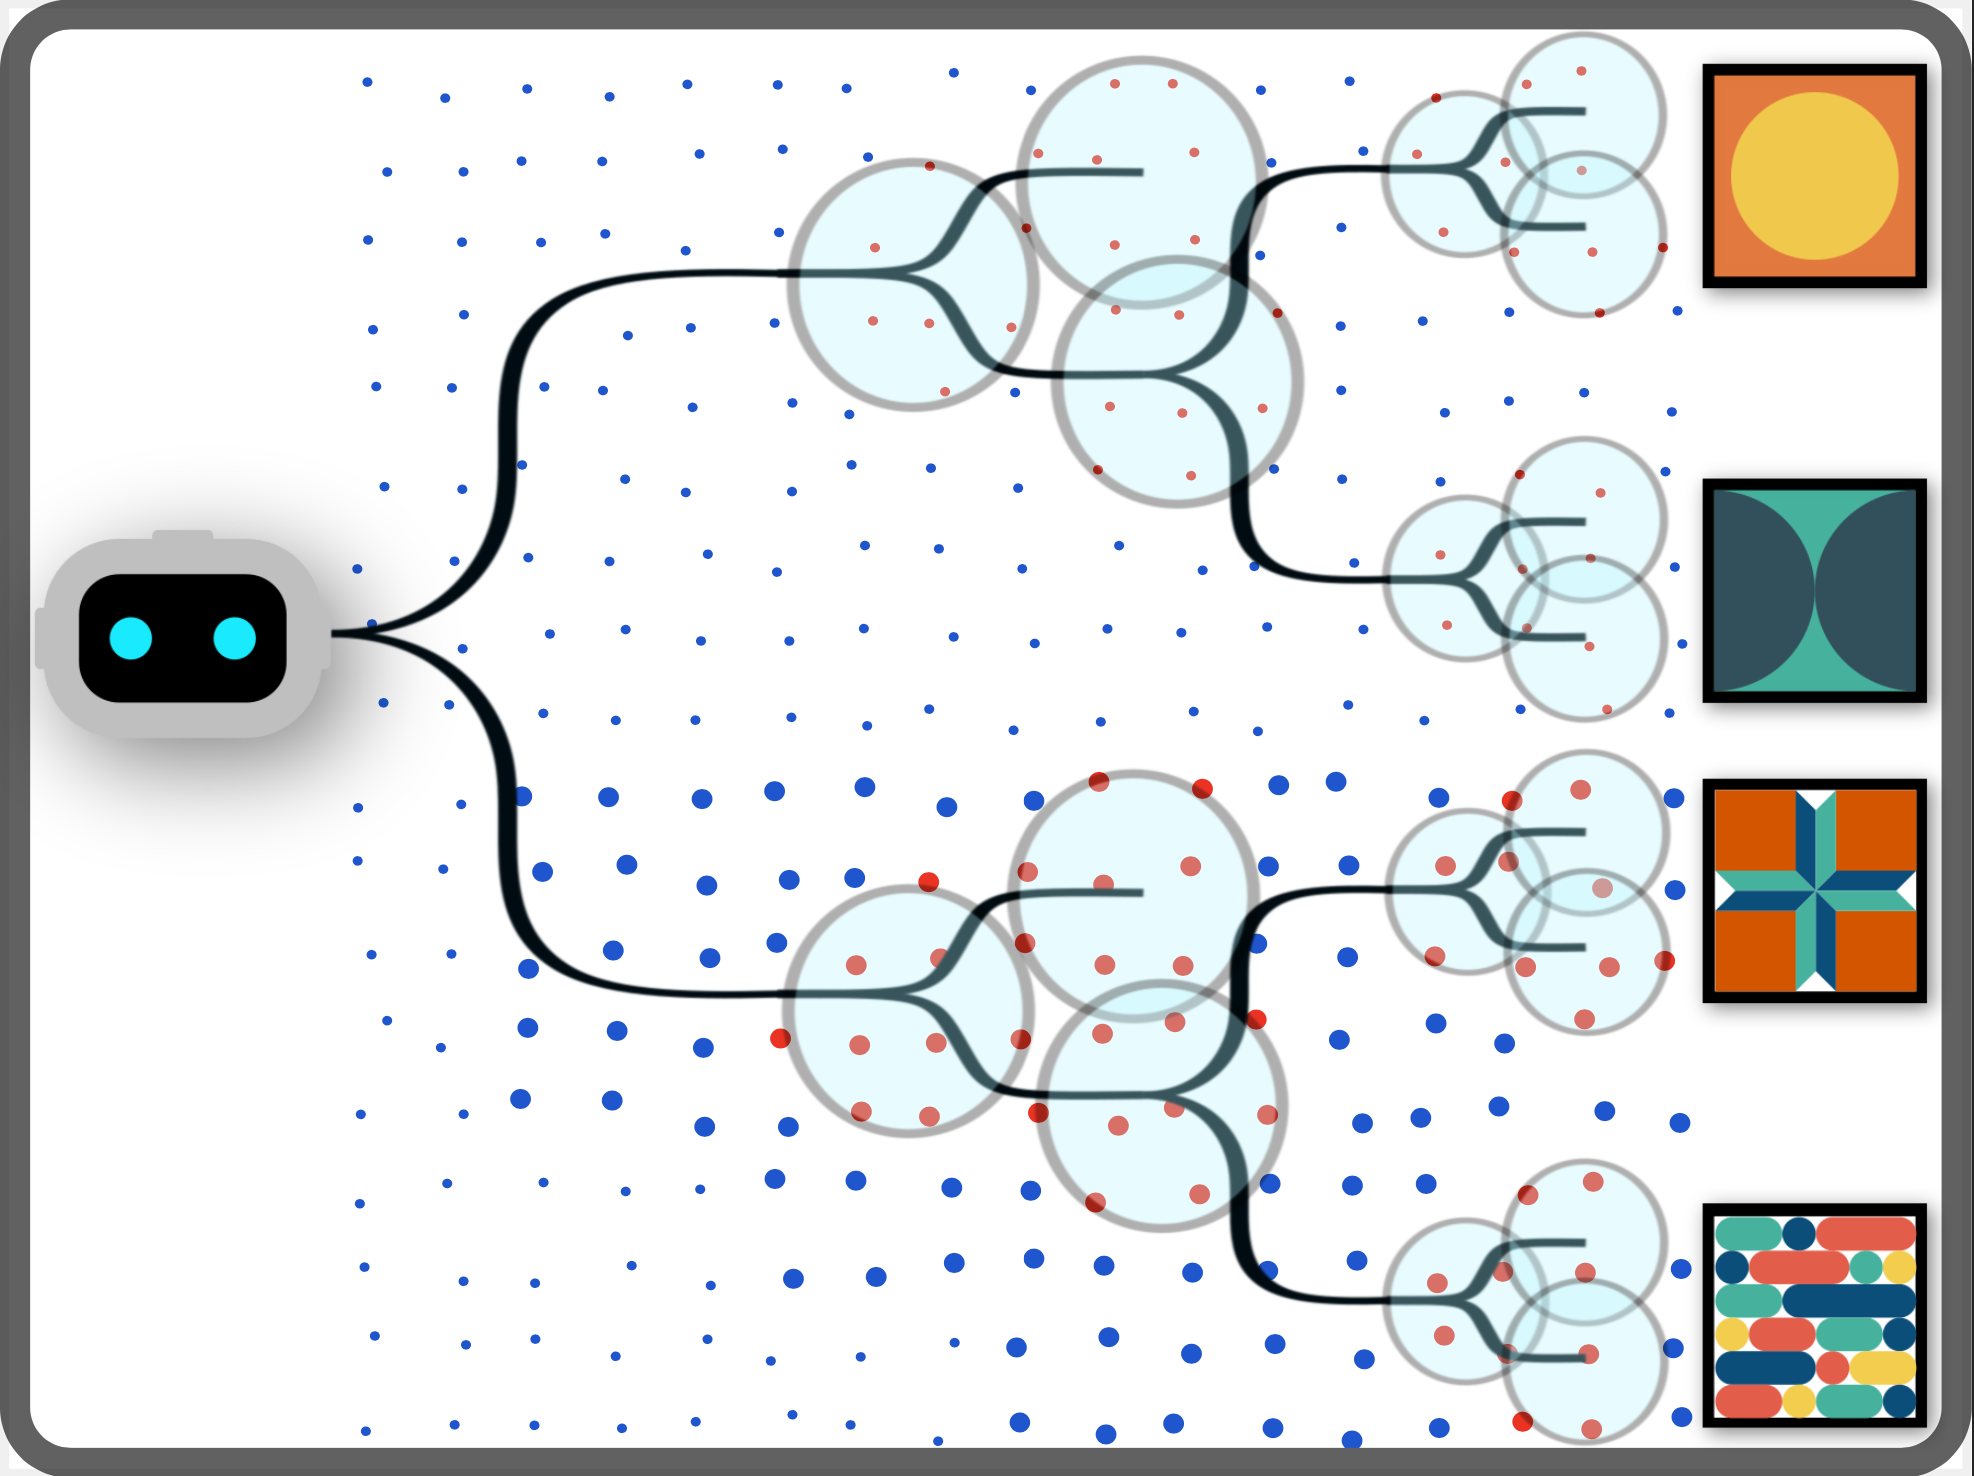
The paper "Accelerated Online Risk-Averse Policy Evaluation in POMDPs with Theoretical Guarantees and Novel CVaR Bounds" has been published in the Journal of Artificial Intelligence Research (JAIR).
www.jair.org/index.php/jair…
Oct 14
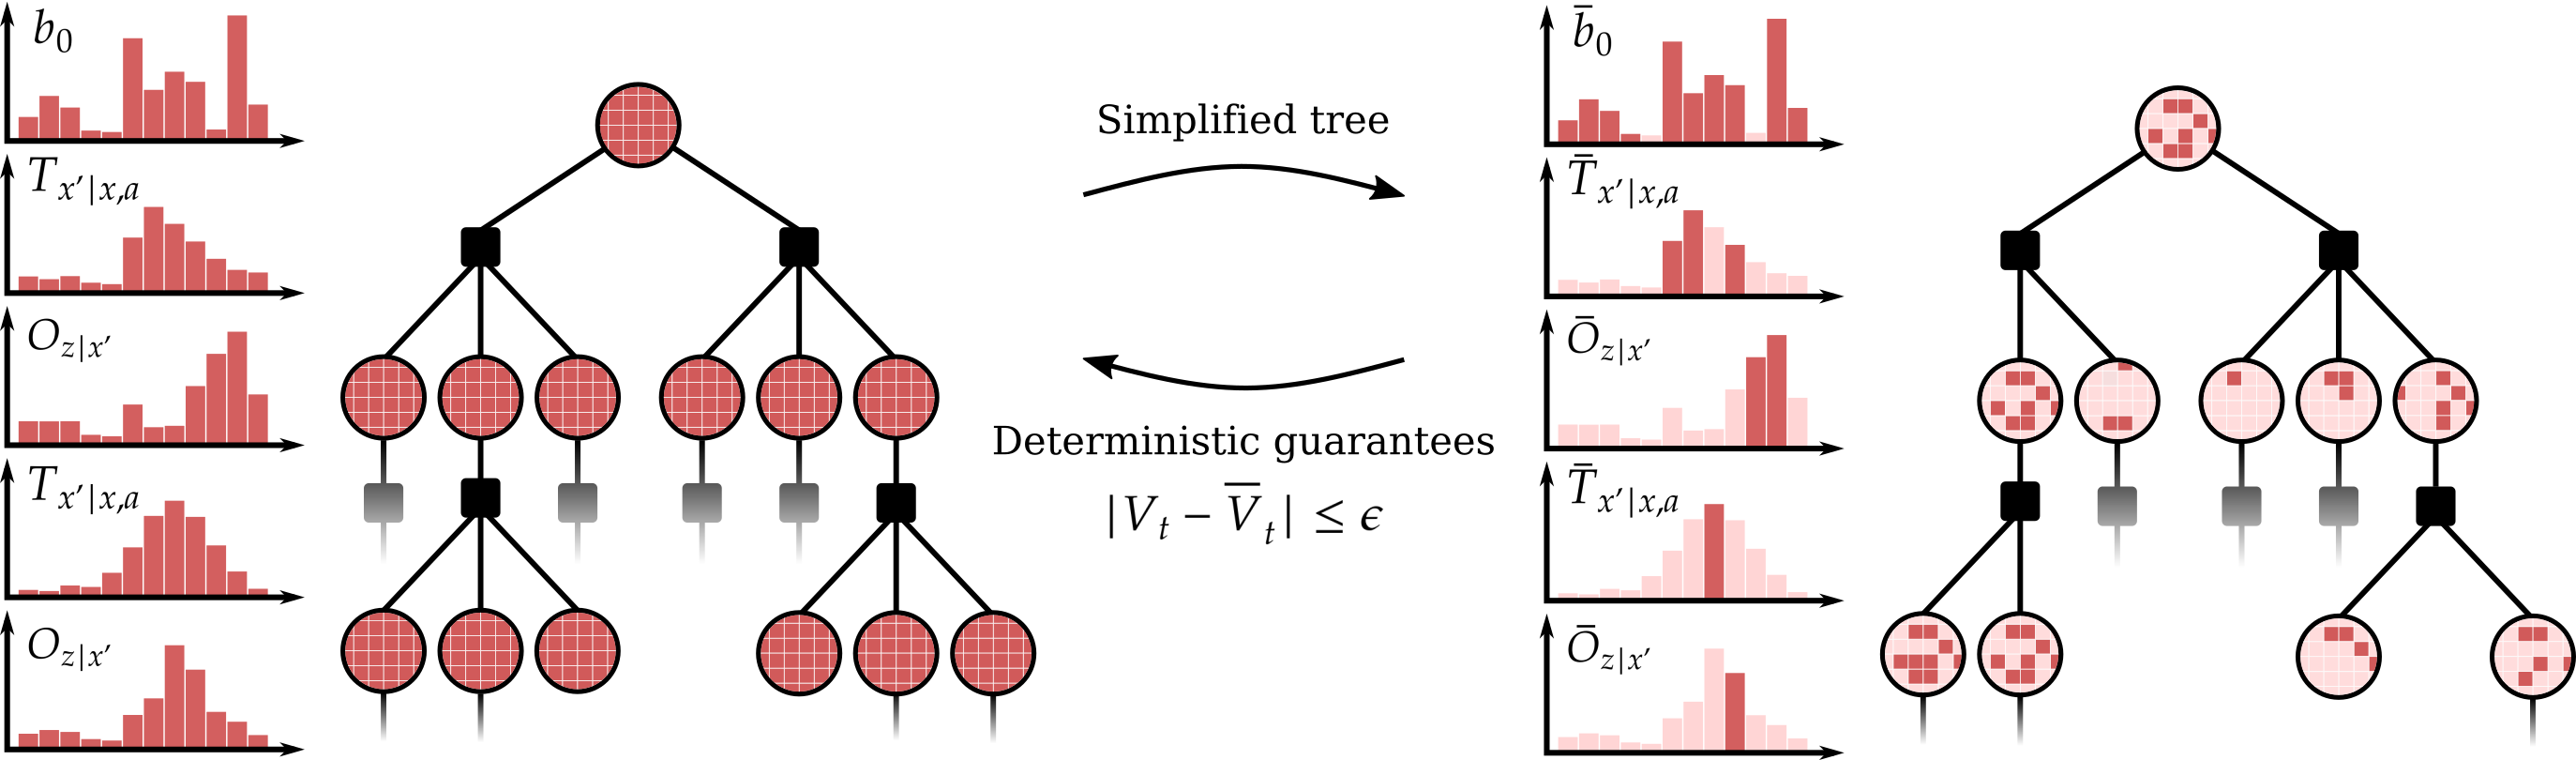
A preprint entitled "Scalable Robust MCTS with Anytime Deterministic Optimality Guarantees" has been published on arXiv.
arxiv.org/abs/2610.15461
Oct 02
The paper "Risk-Averse Online POMDP Planning via CVaR of the Immediate Cost with Performance Guarantees" has been accepted for publication at NeurIPS 2026.
arxiv.org/abs/2609.35874
Oct 02
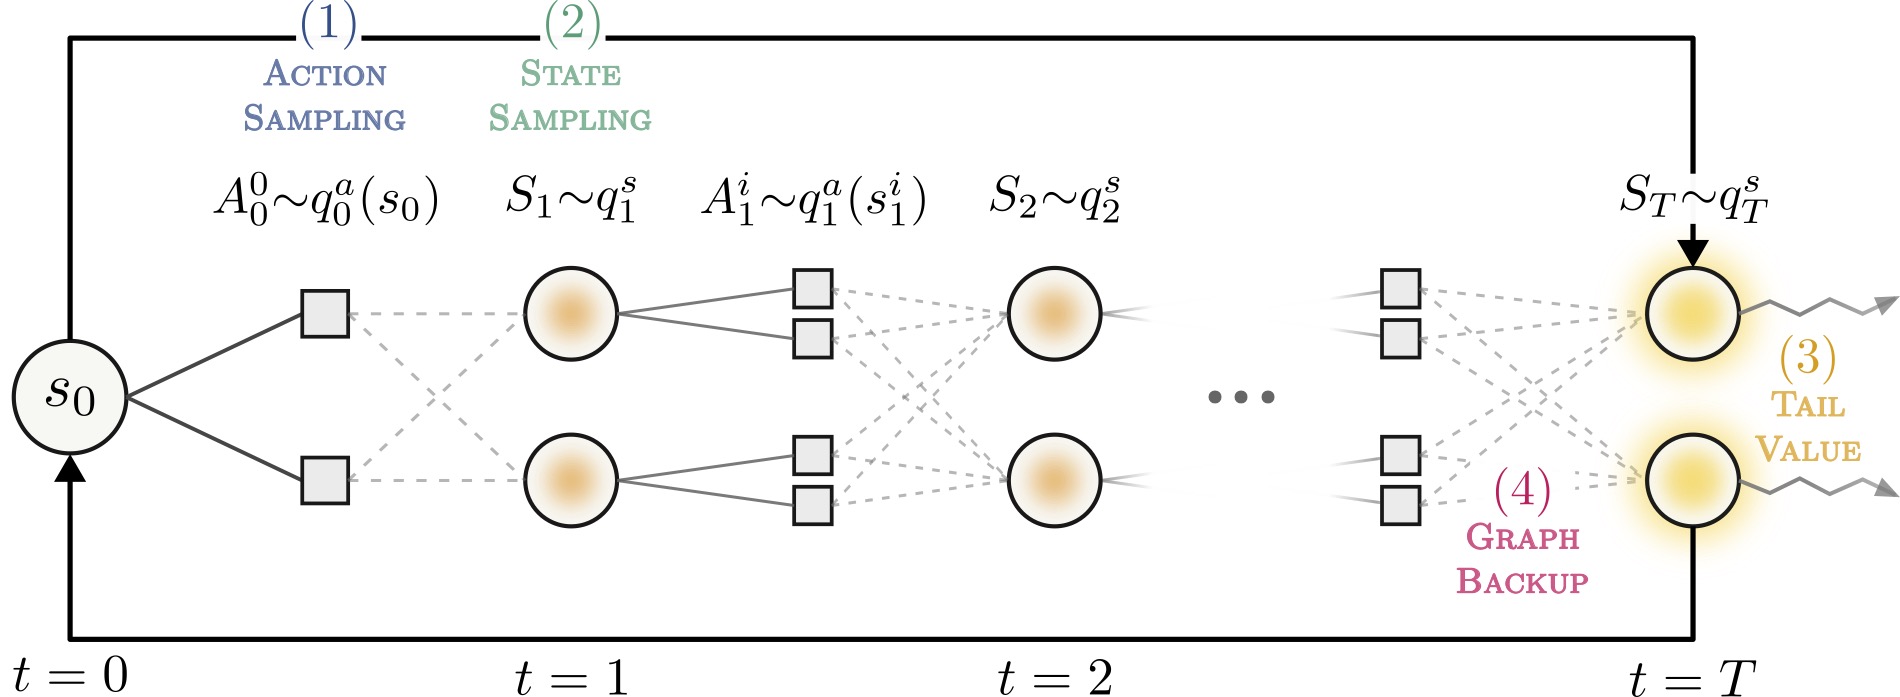
The paper "Graph Sparse Sampling: Breaking the Curse of the Horizon in Continuous MDP Planning" has been accepted for publication at NeurIPS 2026.
arxiv.org/abs/2607.05359
@vadim_indelman
Oct 13
An MSc seminar by Ori Kachanov on "Online Planning in Constrained POMDP"
www.youtube.com/watch?v=_ag…
Aug 16
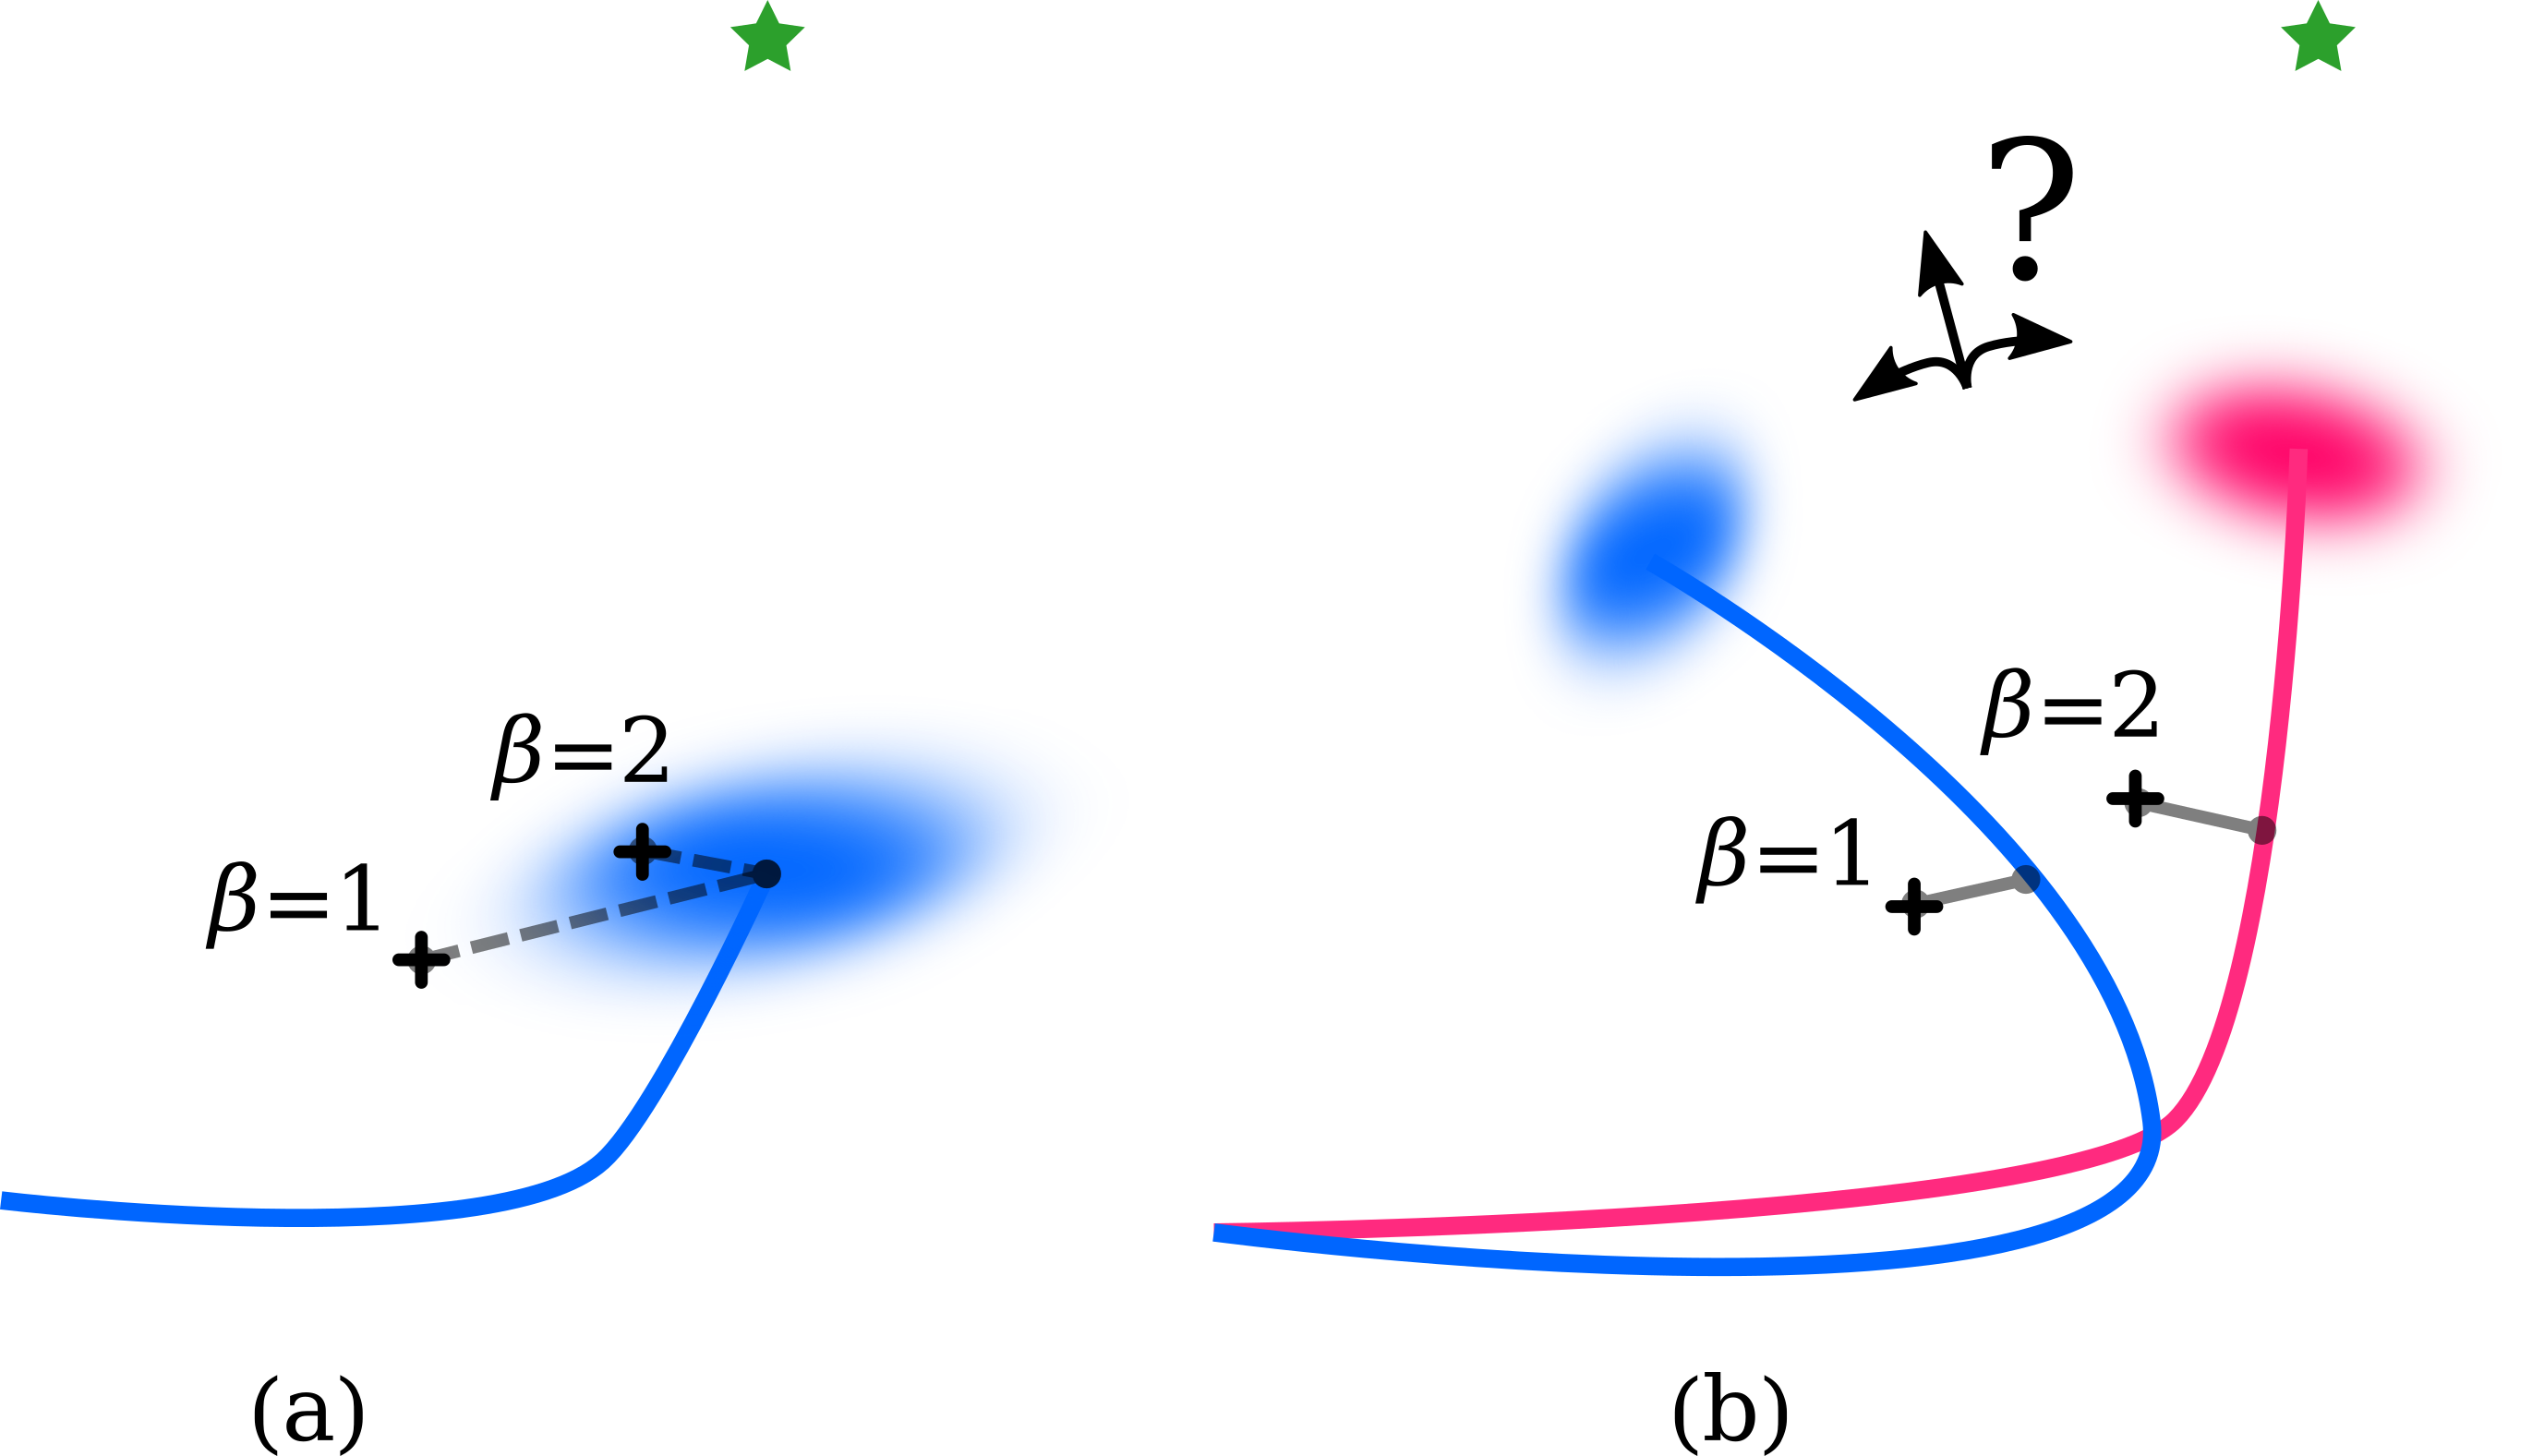
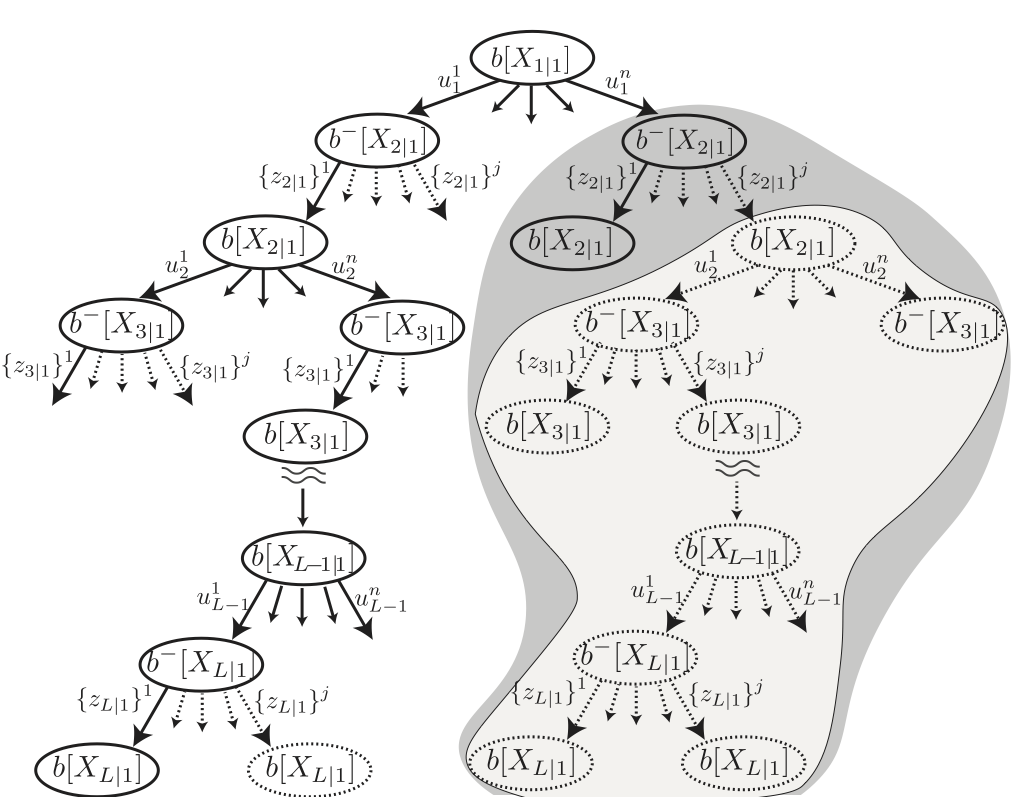
We will present the paper "Action-Gradient Monte Carlo Tree Search for Non-Parametric Continuous (PO)MDPs” at IJCAI-ECAI 2026 this week.
Jun 12
We will present the paper "Open-loop POMDP Simplification and Safe Skipping of Replanning with Formal Performance Guarantees” at WAFR 2026 next week.
lnkd.in/dP7PwTtj
May 24
We will present two recent RA-L and T-RO papers at next week:
lnkd.in/dQPieTTa
lnkd.in/d7ya3NHB
We gratefully acknowledge our funding sources over the years: